PriDex
Human priors for dexterous interaction
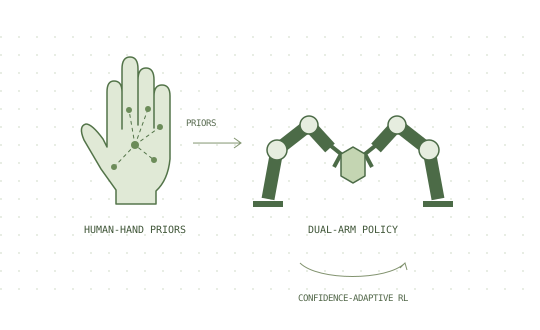
Exploring dual-arm contact-rich manipulation with human-hand priors and confidence-adaptive reinforcement learning fine-tuning. Tasks include pouring, wiping a plate, unscrewing a cap, and sweeping.
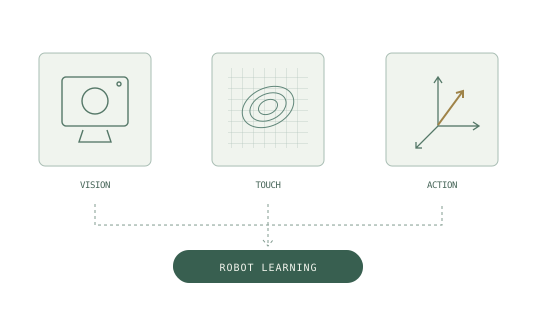
I study how robots can learn dexterous manipulation and human-inspired movement, connecting perception, touch, and action.
My research interests lie at the intersection of robot learning and physical interaction. I’m interested in policies that use visual and tactile feedback to handle contact, and learn from human priors without being limited to imitation.
My current work spans contact-rich dual-arm manipulation, tactile-enhanced vision-language-action policies, reinforcement learning and post-training, and musculoskeletal badminton. I also build tools that make remote robotics research easier.
Selected projects and ongoing investigations.
Human priors for dexterous interaction
Exploring dual-arm contact-rich manipulation with human-hand priors and confidence-adaptive reinforcement learning fine-tuning. Tasks include pouring, wiping a plate, unscrewing a cap, and sweeping.
From human motion to badminton skills
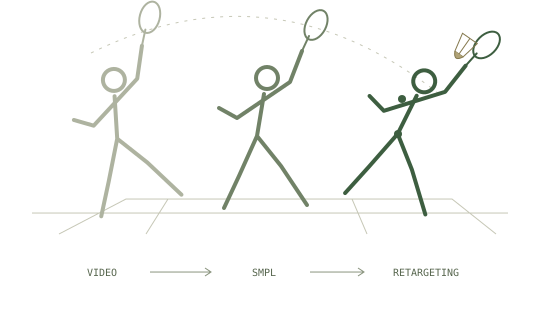
Musculoskeletal badminton research connecting video-based motion reconstruction, retargeting, tracking, and policy distillation with multi-shuttle reinforcement learning and adaptive hitting.
Current focus: the forehand clear. Transfer to full-court humanoid badminton is an ongoing goal.
Connecting perception and physical interaction
I’m interested in tactile-enhanced vision-language-action policies for contact-rich robotic manipulation, and how reinforcement learning and post-training can improve interaction with the physical world.
Research infrastructure
A motion-retargeting pipeline using WHAM, SMPL reconstruction, and joint-limited inverse kinematics, with synchronized previews and Isaac Lab tracking tools.
The public repository validates the pipeline; its smoke tests do not demonstrate a learned badminton skill.
Interested in robot learning, tactile manipulation, or human-inspired movement? I’d love to exchange ideas.
feiyang.yang0627@gmail.com